I'm currently a second-year master's student in Robotics at the GRASP Laboratory, University of Pennsylvania. My research interests span safe localization and planning, vision-language-action models, and reinforcement learning.
Previously in 2025, I completed my B.S. in Computer Engineering and Computer Science at Washington University in St. Louis, where I worked on safe planning with conformalized semantic maps with David Sundarsingh in Prof. Yiannis Kantaros' lab.
News
October 2026
Presenting at IROS 2026
Presenting our IEEE RA-L paper "Safe Planning in Unknown Environments using Conformalized Semantic Maps" and our workshop paper "Memory-Aware Multi-Sensor Perception for Efficient and Safe Navigation in Dynamic Environments" at IROS 2026, including the 2nd LTP Workshop.
September 2026
Workshop paper accepted at IROS 2026
Our work "Memory-Aware Multi-Sensor Perception for Efficient and Safe Navigation in Dynamic Environments" has been accepted to the 2nd LTP Workshop at IROS 2026 and selected for a spotlight presentation.
September 2026
Paper submitted to ICRA 2027
Submitted "Memory-Aware Multi-Sensor Perception for Efficient and Safe Navigation in Dynamic Environments" to the IEEE International Conference on Robotics and Automation (ICRA 2027).
January 2026
Paper accepted at IEEE RA-L
Our work "Safe Planning in Unknown Environments using Conformalized Semantic Maps" has been accepted to IEEE Robotics and Automation Letters.
Education
University of Pennsylvania
M.S.E. in Robotics
Washington University in St. Louis
Cum Laude B.S. in Computer Engineering; B.S. in Computer Science; minor in Psychological & Brain Science
Publications
ICRA 2027
Under Review
Memory-Aware Multi-Sensor Perception for Efficient and Safe Navigation in Dynamic Environments
Li Jingshuo, Yifan Xue, Yifei Li, Shubhodeep Shiv Aditya, Nadia Figueroa
A memory-aware multi-sensor perception framework that leverages temporal memory to enable efficient and safe robot navigation in dynamic environments.
IEEE RA-L 2026
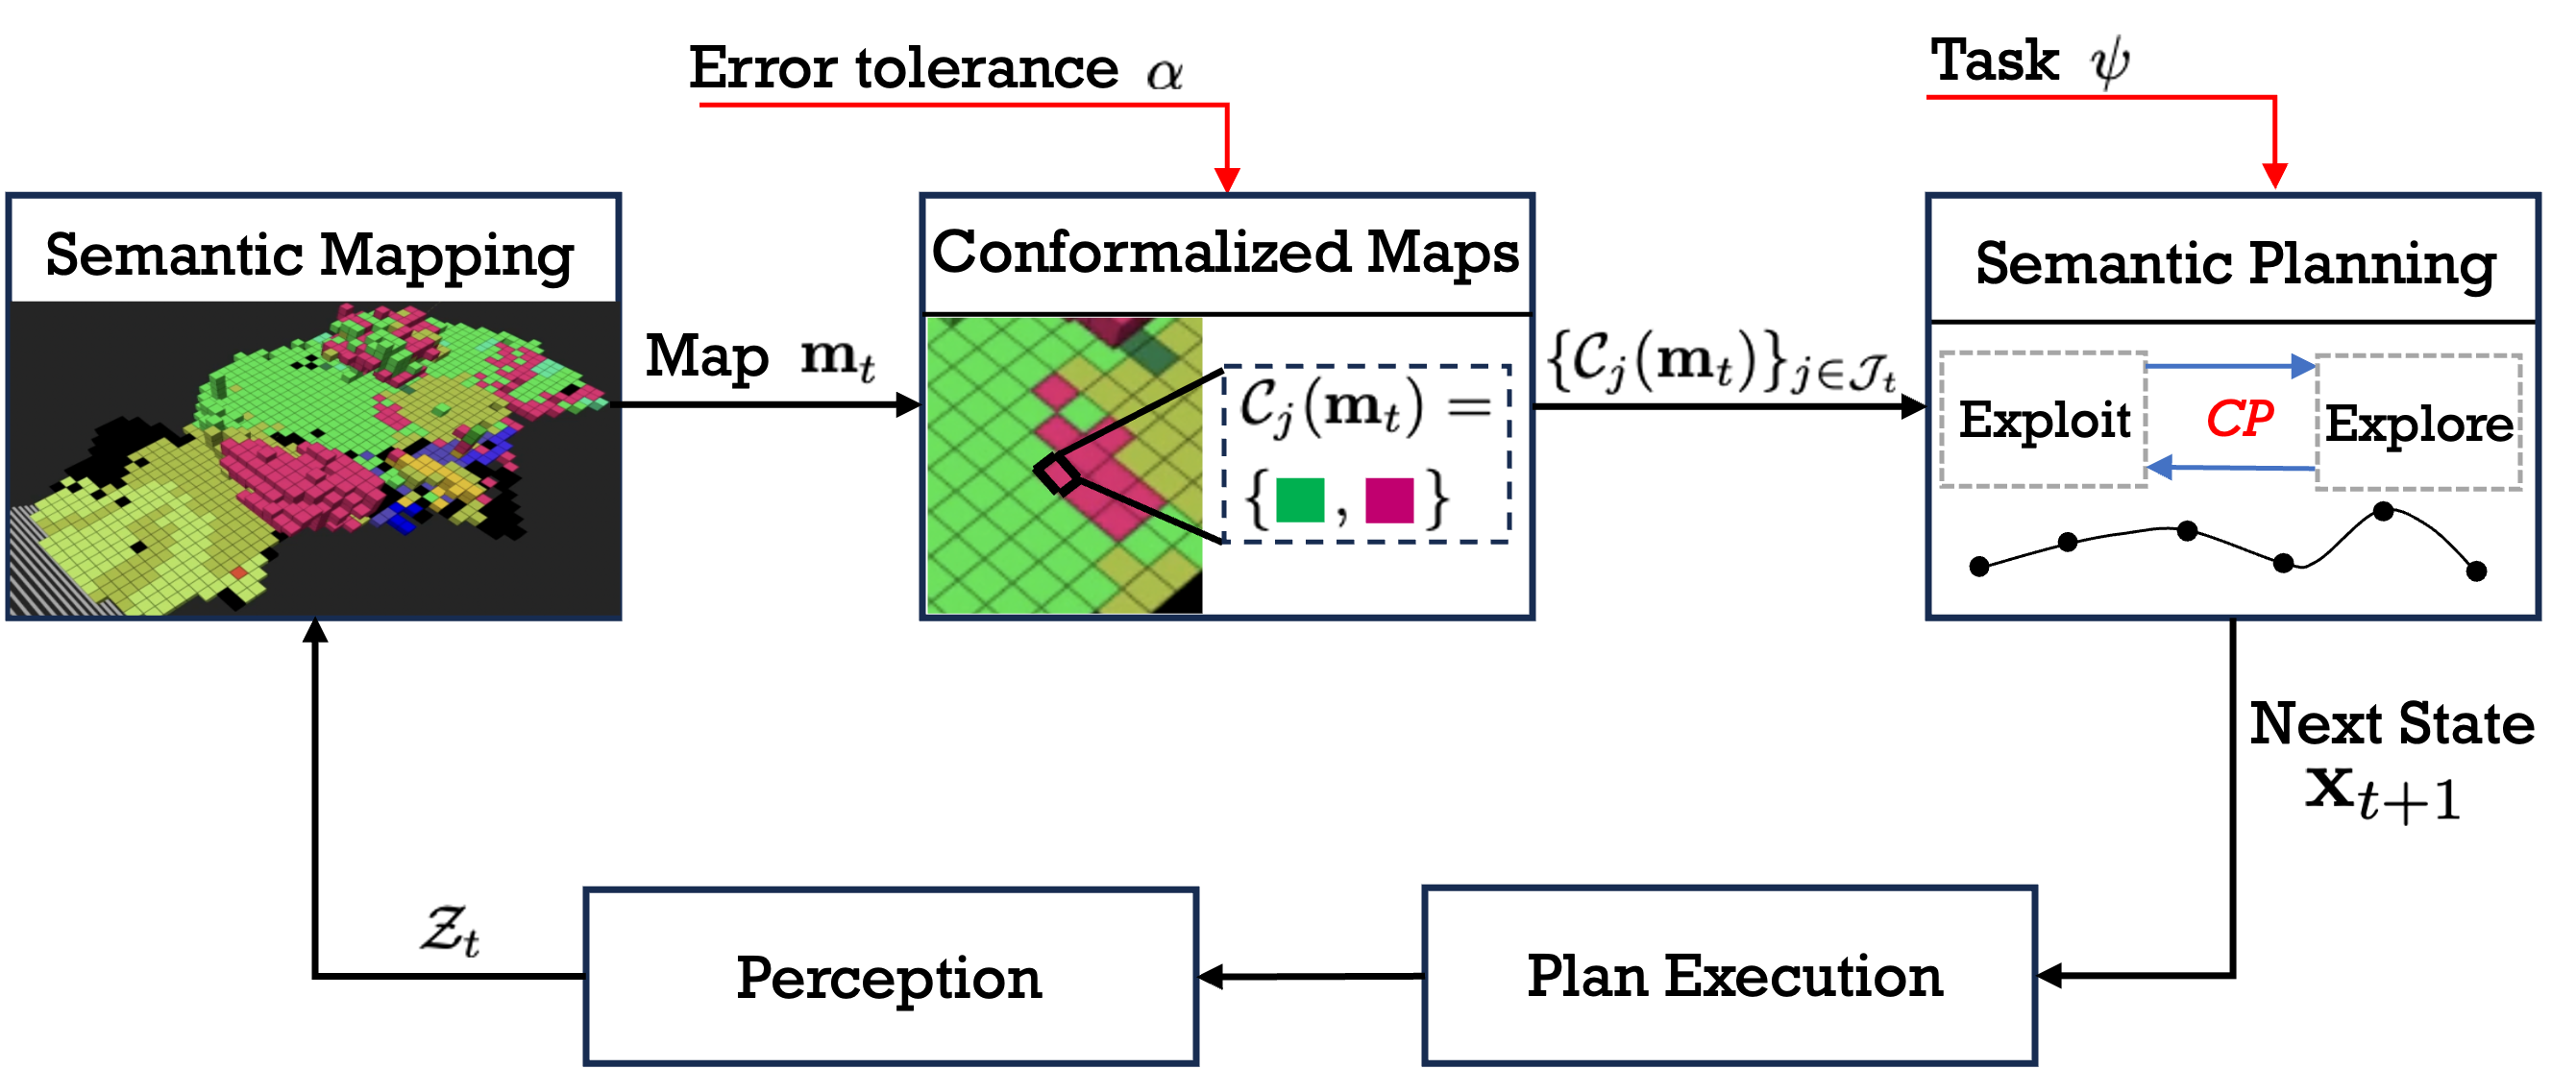
Safe Planning in Unknown Environments Using Conformalized Semantic Maps
David Smith Sundarsingh, Yifei Li, Tianji Tang, George J. Pappas, Nikolay Atanasov, Yiannis Kantaros
A semantic planner for reach-avoid tasks that integrates conformal prediction to quantify semantic map uncertainty without assuming noise distributions, achieving tasks with user-defined probability.
Experience
Undergraduate Researcher — Dr. Yiannis Kantaros's Lab, Washington University in St. Louis
Developed a semantic planner for reach-avoid tasks integrating conformal prediction to quantify semantic map uncertainty. Manuscript accepted to IEEE RA-L.
Assistant in Instruction — Dept. of Computer Science & Engineering, Washington University in St. Louis
Teaching assistant for Data Structures & Algorithms and Video Game Development. Led weekly office hours (20+ students) and discussion sessions; assisted grading and developed grading guides for 60+ TAs.
Intern — Backend Developer — China Industrial Design Institute
Built backend for a digital transformation application using Node.js, Java Spring Boot, and SQL, launching with 5+ initial customers
Portfolio
Reinforcement Learning for Autonomous High-Speed Quadcopter Racing
Implementing PPO in rsl_rl framework and training an autonomous quadcopter racing policy in NVIDIA Isaac Lab.
Autonomous Pick-and-Place with 7-DOF Robot Arm
Full-stack motion planning pipeline using custom FK/IK solvers with null space optimization for the Franka Emika Panda. Achieved 95% success in simulation and 70% on hardware.
HJB-Seeded Learning for Quadrotor Control
Implemented HJB-seeded supervised learning pipeline by solving discretized HJB on a reduced 6D model and deploying on a 12D quadrotor simulator.
Vision-Driven Semantic SLAM and Navigation
Software stack with semantic SLAM on a ground mobile robot for object-directed navigation. Achieved 90% class accuracy and 0.05m localization error.
Multi-Agent Path Finding
Implemented Prioritized Planning and CBS, achieving ~27% fewer node expansions with heuristic-based constraint handling.